
Why is it necessary to recalibrate the zero point after replacing a robot servo motor or reducer?
After replacing servo motors, encoders, reducers, or disassembling joint transmissions, the electrical position and mechanical reference may change, requiring reconfirmation of the mechanical zero point and axis position.
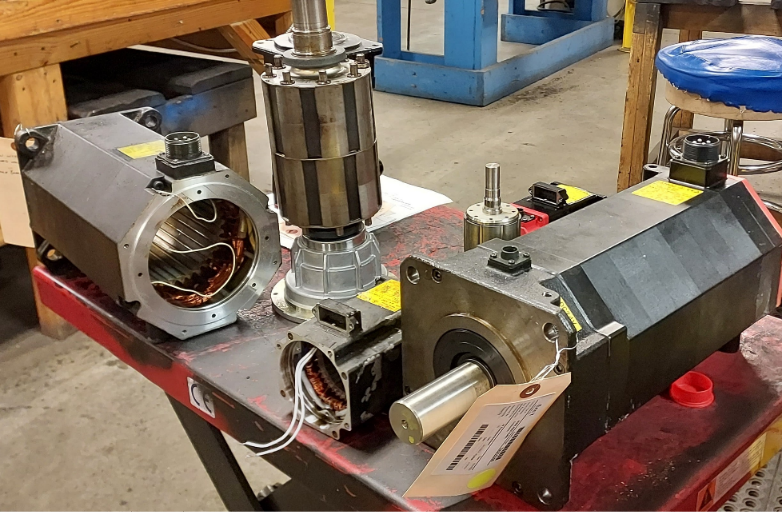
The robot controller calculates joint angles based on encoder data, but the encoder readings must establish a correct correspondence with the mechanical zero position. After the joint transmission is disassembled, even if new components can rotate normally, overall trajectory offset may occur.
- Key Checks
- Confirm whether the current maintenance involved disassembling the motor, encoder, reducer, timing belt, gears, or shaft connecting components.
- Check whether the zero point, revolution counter, machine data, and system were fully backed up before disassembly.
- Verify that the new and old motor encoder types, installation orientation, brakes, and mechanical interfaces are consistent.
- Observe the mechanical marks on each axis, calibration pin holes, or the zero point measurement positions specified by the manufacturer.
- Implementation Steps
- During installation, restore the joint connection according to the specified torque, assembly sequence, and mechanical marks.
- After powering on, perform low-speed jogging first to confirm the direction of motion, brake release status, and soft limit state.
- Update the revolution counter or complete the zero point calibration according to the robot brand's procedure.
- After calibration, verify the tool coordinates, workpiece coordinates, key program points, and safety zones.
- Common Misconceptions
- Only restoring original parameters without checking the mechanical position between the motor shaft and the reducer.
- Directly running the original program at high speed when the zero point is uncertain, which may cause collisions.
- Failing to check tool and workpiece coordinates after calibration is complete, resulting in continued production position offset.
- Summary
After replacing servo motors, encoders, reducers, or disassembling joint transmissions, the electrical position and mechanical reference may change, requiring reconfirmation of the mechanical zero point and axis position.
Industrial Robot Repair Hotline: +86 18122009539
Contact Repair Engineer: +86 18122009539