
How to Calibrate the Robot TCP Tool Center Point? Inspection Methods After Changing Welding Torches and Fixtures
The TCP determines the actual tool position corresponding to the robot program points. After replacing welding torches, fixtures, cutting tools, or flange components, the tool center point should be recalibrated and verified.
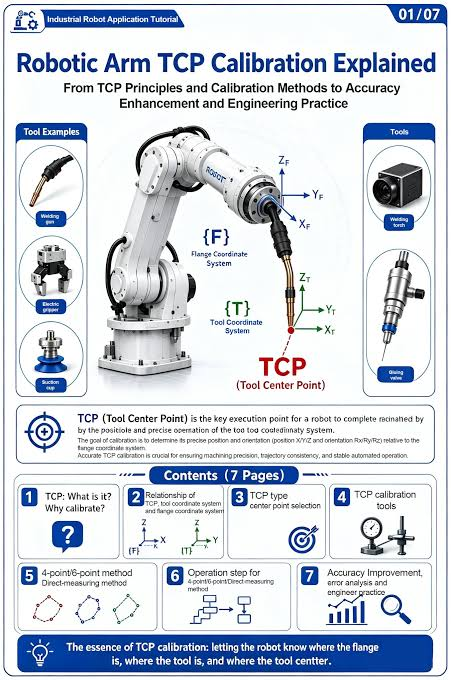
The robot program records the position of the tool coordinate relative to the workpiece. If the tool length, installation angle, or flange connection changes, even if the original program points are not modified, the actual machining position will shift.
- Key Inspection Points
- Confirm whether the tool has been reinstalled, collided, repaired, or had its torch neck, gripper jaws, or adapter plate replaced.
- Check if the flange mounting surface, locating pins, and fastening bolts are clean and properly installed.
- Select a fixed sharp point or calibration device, and ensure the reference point itself has not moved.
- During calibration, use a sufficient number of robot poses with significantly different orientations.
- Procedure Steps
- First, establish or confirm the correct tool weight, center of gravity, and load data.
- Follow the controller procedure to collect data from the same fixed reference point across multiple poses.
- Save the new TCP and compare it with the old value, checking if the changes in length and direction are reasonable.
- Verify the calibration result by approaching the same point from different poses and running the actual process trajectory.
- Common Mistakes
- Using only a single pose for visual alignment cannot accurately calculate the TCP.
- A loose calibration point or a worn tool tip leads to deviations in all sampled data.
- After modifying the TCP, failing to check the original program's safety distances and approach paths.
- Summary
The TCP determines the actual tool position corresponding to the robot program points. After replacing welding torches, fixtures, cutting tools, or flange components, the tool center point should be recalibrated and verified.
Industrial Robot Repair Hotline: +86 18122009539
Contact Repair Engineer: +86 18122009539