
What is the relationship between robot base coordinates, workpiece coordinates, and tool coordinates? On-site application explanation.
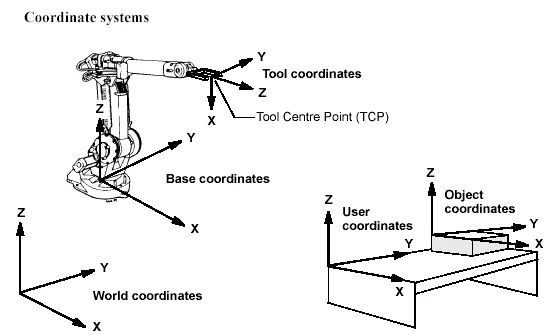
Base coordinates describe the positional relationship of the robot or external equipment, workpiece coordinates describe the product datum, and tool coordinates describe the end effector; together, these three determine the actual position of program points.
In this article
On-site positional deviations are not necessarily due to mechanical accuracy. An error in the setting of any one of the tool coordinates, workpiece coordinates, or base coordinates can cause a consistent offset or change in posture for an entire program segment.
- Key Inspection Points
- Tool coordinates define the position and orientation from the flange to the Tool Center Point (TCP).
- Workpiece coordinates define the machining datum for the product, fixture, or workbench.
- Base coordinates are used to describe the spatial relationship of the robot base, floor track, positioner, or other equipment.
- For coordinated external axis applications, it is also necessary to ensure that both the mechanical zero point and the coordinate relationships are correct.
- Troubleshooting Steps
- First, confirm the robot's mechanical zero point and base installation status before performing coordinate calibration.
- Calibrate the TCP after tool changes, and re-calibrate workpiece coordinates after fixture movement.
- Use multiple known points to check coordinate direction, origin, and rotational relationships.
- After modifying coordinates, verify key program points, safety zones, and the complete process trajectory.
- Common Misconceptions
- Modifying the program point-by-point after discovering an entire trajectory offset, without checking the coordinates.
- Modifying both tool coordinates and workpiece coordinates simultaneously, making it difficult to identify the source of error.
- Continuing to use the original base coordinates and workpiece coordinates after relocating the robot.
- Summary
Base coordinates describe the positional relationship of the robot or external equipment, workpiece coordinates describe the product datum, and tool coordinates describe the end effector; together, these three determine the actual position of program points.
Industrial Robot Repair Hotline: +86 18122009539
Contact Repair Engineer: +86 18122009539
Need a part or repair assessment?
Share the robot model, part number, fault details and destination country with our team.
Contact our team ↗