
What are the manifestations of a loose robot base? Vibration, accuracy, and base foot inspection
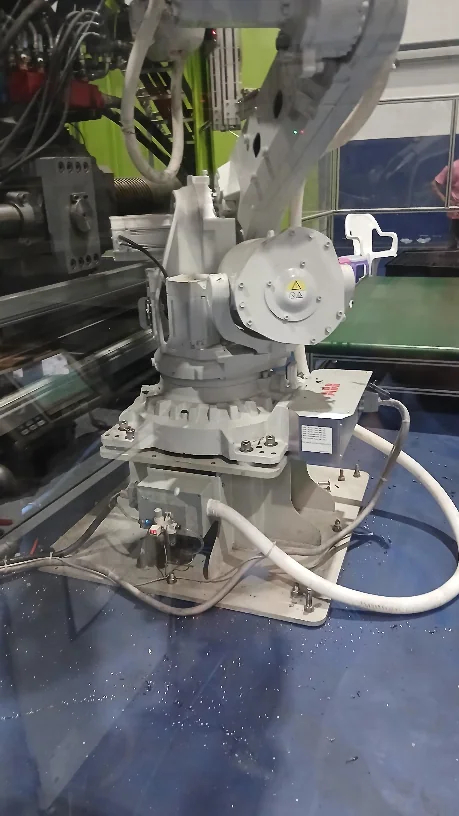
Looseness in the robot base or base foot connections can cause vibration, trajectory deviation, changes in repeat positioning, and mechanical shock. The foundation, bolt preload, and mounting surface should be inspected.
In this article
The inertial loads generated by the robot's high-speed starts and stops continuously act on the base. If the foundation strength, mounting surface, or base foot preload is insufficient, the problem may gradually worsen with operating time.
- Key Inspection Points
- Check for gaps, corrosion, or signs of movement between the base and the mounting plate.
- Inspect the tightening status of base foot bolts, locating pins, and mounting plates according to regulations.
- Observe whether vibration is noticeably more pronounced during arm extension, high-speed direction changes, or heavy-load movements.
- Compare repeat positioning results at different positions and from different approach directions.
- Handling Steps
- After stopping the machine and supporting the equipment, check if the foundation and mounting surface are cracked or deformed.
- Re-tighten the connecting components in the sequence and to the torque specified by the manufacturer.
- If necessary, re-calibrate the base level, mechanical position, and base coordinate system.
- After handling, perform verification tests at low speed, high speed, no-load, loaded conditions, and for accuracy.
- Common Misconceptions
- When investigating robot vibration, only checking the reducer and motor while neglecting base connections.
- Arbitrarily increasing bolt torque, causing damage to threads or the mounting plate.
- Failing to reconfirm coordinates and safety zones after the base position has changed.
- Summary
Looseness in the robot base or base foot connections can cause vibration, trajectory deviation, changes in repeat positioning, and mechanical shock. The foundation, bolt preload, and mounting surface should be inspected.
Industrial Robot Repair Hotline: +86 18122009539
Contact Repair Engineer: +86 18122009539
Need a part or repair assessment?
Share the robot model, part number, fault details and destination country with our team.
Contact our team ↗