
What are the responsibilities of servo drives, servo motors, and encoders? Troubleshooting approach
The servo drive is responsible for power and control, the servo motor is responsible for generating motion, and the encoder is responsible for position feedback; fault phenomena of the three may affect each other, requiring judgment based on alarms and measurements.
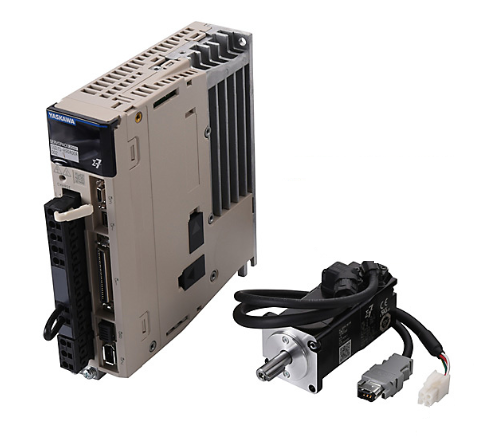
When a robot single axis cannot be enabled, runs with jitter, or has positioning abnormalities, the drive is often replaced directly on-site. In reality, motor windings, encoders, cables, and mechanical loads can all cause the drive to generate protective alarms.
- Key Checks
- The drive receives control commands and regulates output current, voltage, and motor motion status.
- The servo motor converts electrical energy into torque and maintains axis position when stopped via the brake.
- The encoder feeds back motor shaft position and speed to the control system, forming closed-loop control.
- Power cables, feedback cables, mechanical jamming, and parameter errors can simultaneously affect the performance of all three.
- Implementation Steps
- First, record the complete alarm, faulty axis, robot posture, speed, and load conditions.
- Check power supply, drive indicators, power line insulation, encoder lines, and brake circuits.
- When conditions permit and models are consistent, narrow down the fault scope through standardized cross-verification.
- After repair, perform low-speed, reverse, no-load, loaded, and temperature rise tests.
- Common Misconceptions
- Judging the drive is damaged upon seeing an overcurrent alarm, ignoring motor short circuits or mechanical jamming.
- Only replacing the encoder for an encoder alarm, without checking the feedback cable and connectors.
- Not restoring parameters, zero points, and load settings after component replacement.
- Summary
The servo drive is responsible for power and control, the servo motor is responsible for generating motion, and the encoder is responsible for position feedback; fault phenomena of the three may affect each other, requiring judgment based on alarms and measurements.
Industrial Robot Repair Hotline: +86 18122009539
Contact Repair Engineer: +86 18122009539