
How to Diagnose ABB Servo Motor Repairs? Encoder, Brake, Bearing, and Winding Inspection
ABB servo motor faults should be diagnosed by combining encoder feedback, brake operation, bearing noise, winding insulation, and temperature rise tests to distinguish between motor, cable, and drive issues.
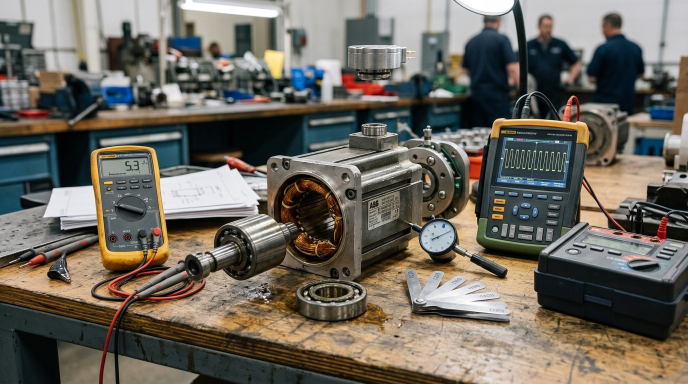
When an ABB robot exhibits single-axis alarms, abnormal operating noises, positioning deviations, or motor overheating, the fault may not originate from the servo motor itself. Before repair, it is necessary to simultaneously inspect the drive unit, power cables, feedback cables, mechanical load, and brake circuit.
- Encoder and Feedback Inspection
Record encoder communication, position deviation, and zero-point related alarms. Check the feedback plug, shield grounding, cable bending, and pin condition. If alarms occur only in specific postures, priority should be given to inspecting the robot body wiring harness and flexible cables.
- Brake Inspection
Issues such as a robot axis failing to release, slow drifting after shutdown, or significant impact during startup may be related to the brake coil, rectified power supply, brake gap, or mechanical wear. During inspection, reliable support should be used to prevent accidental axis movement.
- Bearing and Mechanical Condition
Observe noise, vibration, and temperature rise by running a single axis at low speed, and compare with other axes or historical data. Bearing damage, loose coupling structures, and reducer resistance can all cause increased current.
- Winding and Insulation Testing
After powering off and isolating the drive, measure the three-phase resistance balance and insulation to ground. The testing method and voltage level should comply with the motor and encoder requirements to prevent damage to feedback devices during testing.
- Post-Repair Verification
After repair, recheck connectors, brake release, encoder status, and mechanical installation. Complete low-speed, rated load, repeat positioning, temperature rise, and continuous operation tests.
ABB servo motor repair should be based on measurement results, first eliminating cables, drives, and mechanical loads before determining the scope of work for bearings, brakes, encoders, or windings.
Industrial Robot Repair Hotline: +86 18122009539
Contact Repair Engineer: +86 18122009539