ABB Robot Repair · 2026-09-10
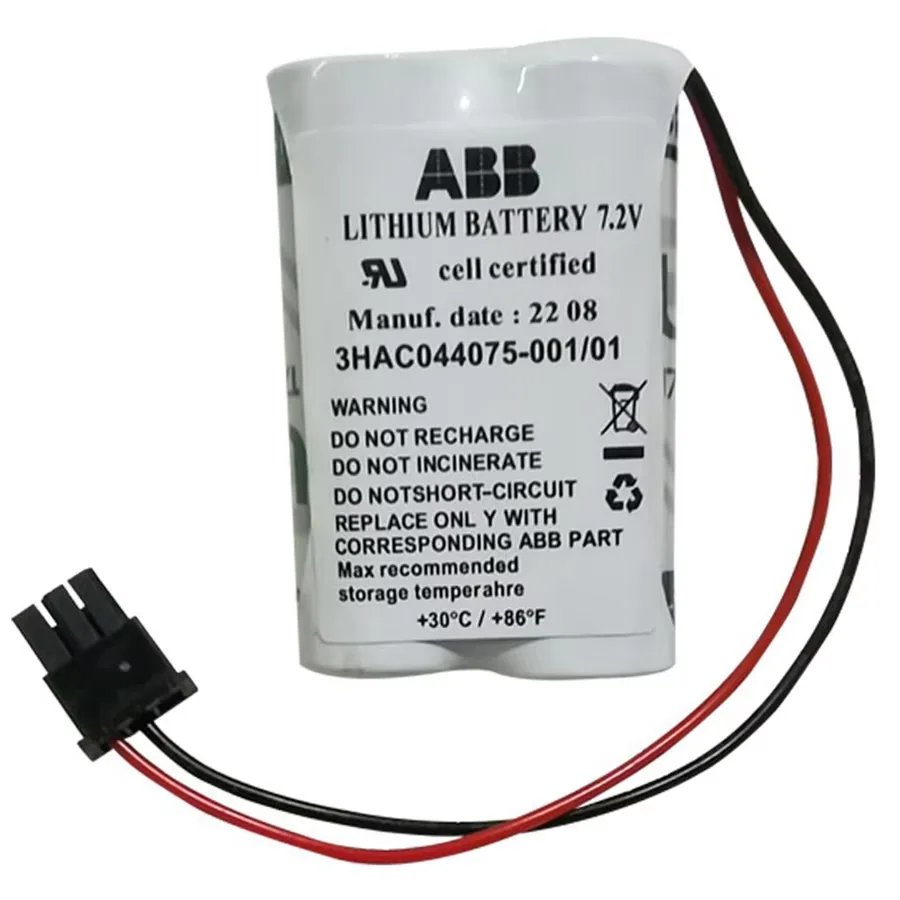
Industrial robot encoder backup batteries are used to maintain the absolute position data of each axis after the controller is powered off. Insufficient battery voltage, loose connectors, or incorrect replacement methods may cause encoder alarms, revolution counter loss, and robot zero point shift. This article introduces the recommended replacement cycle for encoder batteries, handling methods for different alarm stages, and the verification process after replacement.
Read article →
ABB Robot Repair · 2026-09-10
After the filter pads in an industrial robot control cabinet become clogged or the cooling fan speed decreases, it may cause internal temperature rise, drive overheating, controller restarts, and communication abnormalities. This article introduces the recommended maintenance intervals for control cabinet filter pads and fans, fault diagnosis, replacement requirements, and post-repair cooling verification methods.
Read article →
ABB Robot Repair · 2026-09-10
There is no unified replacement interval for industrial robot lubricating oil and grease. It should be determined based on the robot model, joint position, cumulative operating hours, workload, and on-site environment. This article introduces robot gearbox lubrication intervals, abnormal oil condition assessment, maintenance methods under different operating conditions, and the recommissioning inspection process after an oil change.
Read article →
ABB Robot Repair · 2026-09-09
After an industrial robot has accumulated 10,000 hours of operation, the reducer lubrication, joint clearance, servo motors, brakes, body cables, encoder batteries, and control cabinet cooling systems may exhibit varying degrees of aging. This article introduces the 10,000-hour maintenance items, inspection sequence, fault diagnosis, and recommissioning acceptance methods for robots.
Read article →
ABB Robot Repair · 2026-09-09
After continuous operation of ABB industrial robots, mechanical joints, reducers, servo motors, body cables, encoder batteries, and the IRC5 control cabinet gradually experience issues such as lubrication aging, component loosening, reduced heat dissipation, and changes in positioning accuracy. This article compiles the ABB robot annual maintenance checklist, introducing pre-maintenance backup, mechanical body inspection, lubrication maintenance, electrical testing, safety function verification, and restart validation methods.
Read article →
ABB Robot Repair · 2026-09-09
The RDC in KUKA KR C4 robots is responsible for collecting position feedback from each axis and storing robot-specific machine data and calibration information. Abnormalities in the RDC, battery, feedback cables, or connectors can lead to zero point loss, encoder communication faults, servo enable failure, and program trajectory deviation. This article introduces methods for RDC fault diagnosis, line inspection, machine data verification, EMD calibration, and post-repair verification.
Read article →
ABB Robot Repair · 2026-09-09
When a FANUC R-30iB robot communicates with a PLC via EtherNet/IP, issues such as device dropout, complete failure of digital I/O, connection timeouts, repeated switching of communication status, or inability to start the robot program may occur. This article introduces systematic troubleshooting methods covering the physical link, IP addresses, Scanner and Adapter roles, Assembly parameters, RPI cycle, and I/O mapping.
Read article →
ABB Robot Repair · 2026-09-09
When the 24V control power supply in a Yaskawa YRC1000 robot control cabinet is abnormal, it may cause the teach pendant to have a black screen, the controller to fail to start, I/O modules to go offline, safety circuit abnormalities, or servo enable failure. This article introduces the 24V power supply chain, segmented output load inspection, short circuit judgment, communication fault correlation analysis, and load verification methods after repair.
Read article →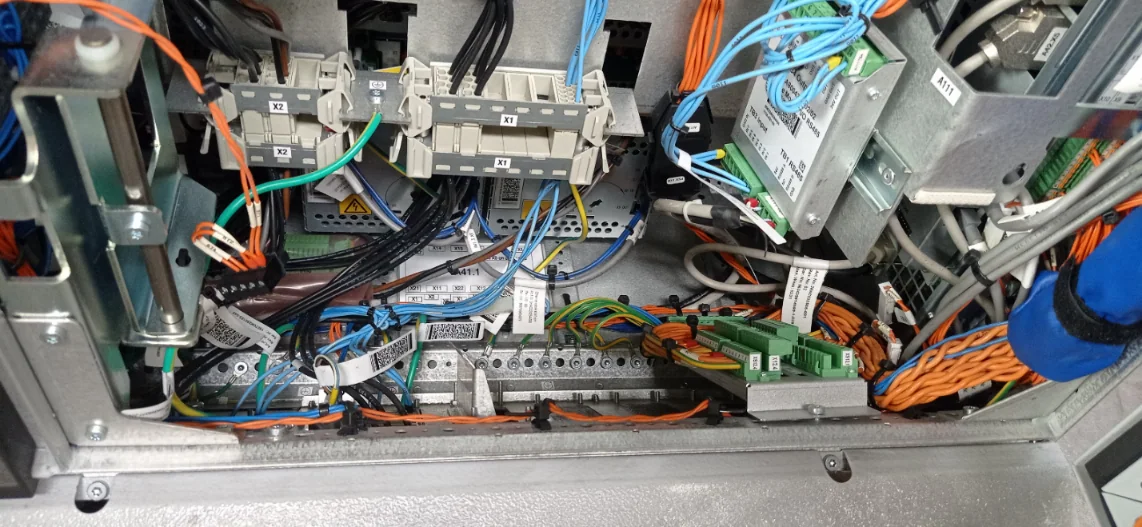
ABB Robot Repair · 2026-09-09
When a fault occurs in the DSQC661 power supply unit within the ABB IRC5 control cabinet, it may lead to the main computer failing to boot, the teach pendant screen going black, control module communication interruption, system repeated restarts, or the robot being unable to be enabled. This article focuses on the DSQC661 3HAC026253-001, introducing methods for input power supply, output load, connection wiring, internal circuitry, and post-repair verification under load.
Read article →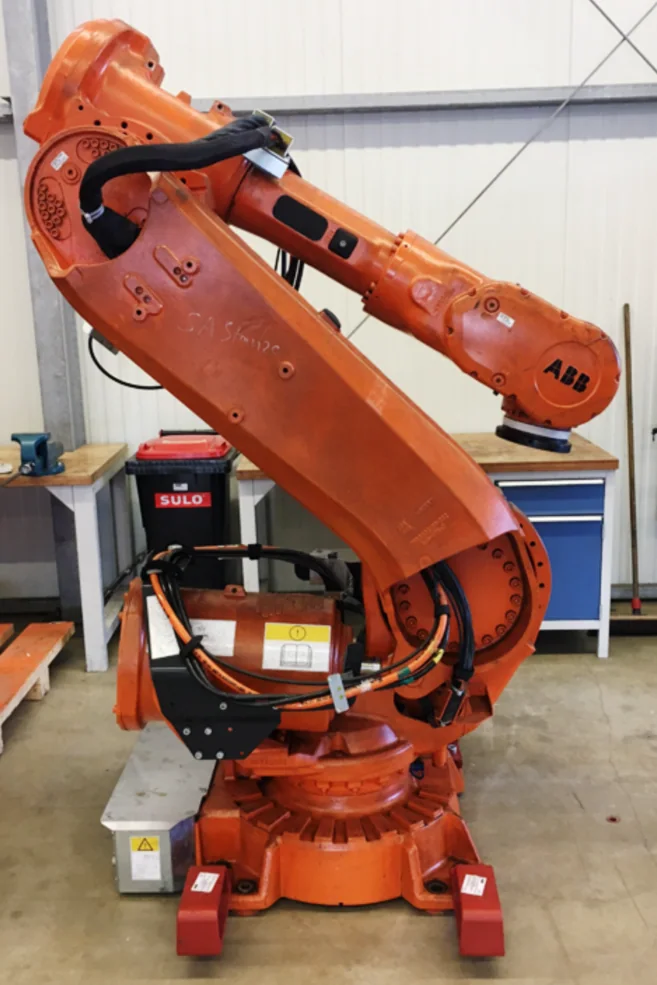
ABB Robot Repair · 2026-09-09
An ABB IRB 6640 robot at an automotive parts company in Chongqing could operate at low speeds, but frequently triggered collision alarms when speed was increased. The Axis 2 servo motor and lubricating oil had been replaced previously, but the fault persisted. Further on-site inspection revealed abnormal oil condition and significant debris in the Axis 2 reducer, with noticeable sticking during no-load rotation. The Axis 2 reducer unit was ultimately confirmed as faulty.
Read article →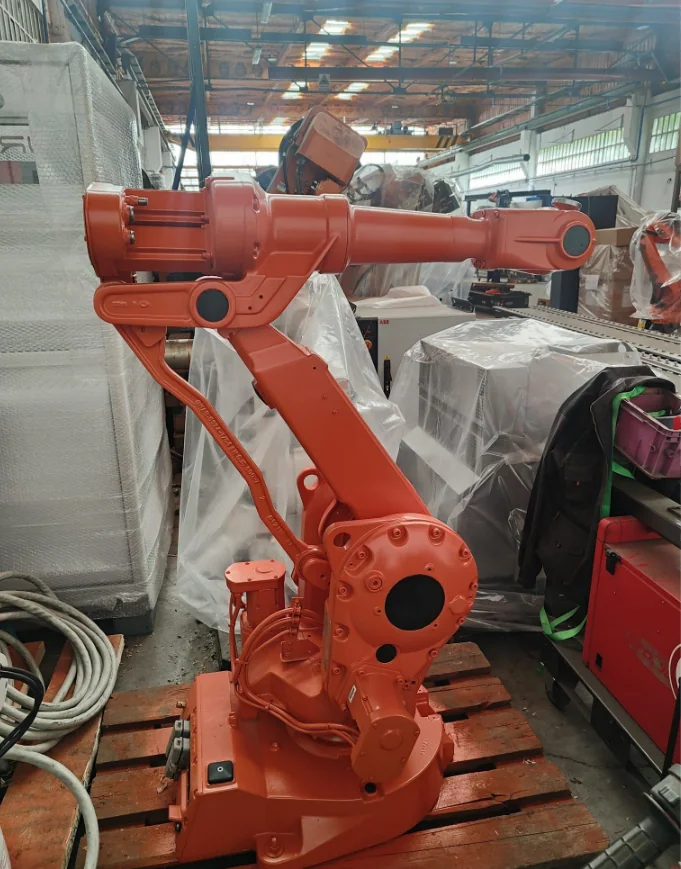
ABB Robot Repair · 2026-09-09
After long-term operation of the ABB IRB 4600 robot, wear, aging, and abnormal heat dissipation may occur in the manipulator joints, reducers, servo motors, brakes, manipulator cables, and the IRC5 controller cabinet. This article introduces the preparation work for IRB 4600 annual maintenance, mechanical manipulator inspection, lubrication maintenance, electrical testing, zero point verification, and restart procedures.
Read article →
ABB Robot Repair · 2026-09-09
After an ABB IRBP R positioner is integrated with an IRC5 robot to form a coordinated welding system, faults such as the external axis failing to enable, rotational position deviation, desynchronization between the robot and the positioner, encoder alarms, or zero point loss may occur. This article introduces the troubleshooting methods for the external axis's drive and feedback chain, mechanical unit configuration, brake, encoder, reducer, and coordinated motion.
Read article →