Robot Information · 2026-09-14
Repeatability reflects the consistency of a robot returning to the same point multiple times, while absolute positioning accuracy reflects the deviation between the commanded position and the actual spatial position. Their purposes and inspection methods differ.
Read article →
Robot Information · 2026-09-14
When purchasing a used industrial robot, simultaneously check mechanical backlash, reducer noise, servo system, control cabinet, teach pendant, zero point data, and loaded operation status.
Read article →
Robot Information · 2026-09-14
Industrial robot spare parts should not be purchased based on price alone. Inventory should be established by classification, considering factors such as the impact of failure downtime, delivery lead time, commonality, and historical consumption, to reduce waiting time during unexpected shutdowns.
Read article →
Repair Guide · 2026-09-12
When the ABB 3HAC024386-001 body cable experiences broken cores, wear, or poor connector contact, it often manifests as robot-specific posture alarms and intermittent signal interruptions.
Read article →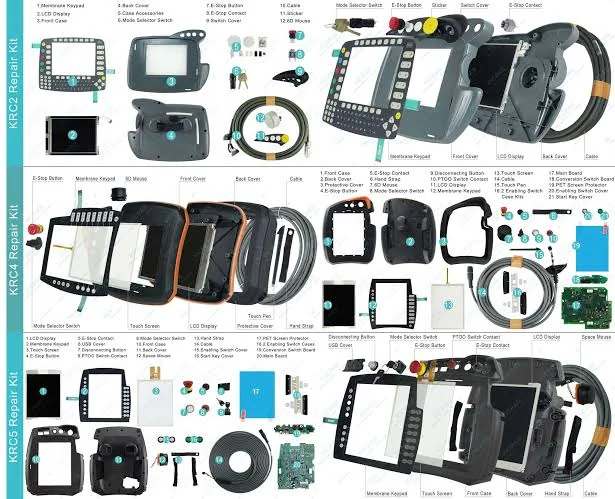
Repair Guide · 2026-09-12
When a KUKA smartPAD experiences a black screen, touch failure, abnormal buttons, or communication interruption with the control cabinet, the power supply, connection cables, emergency stop, and internal components should be checked.
Read article →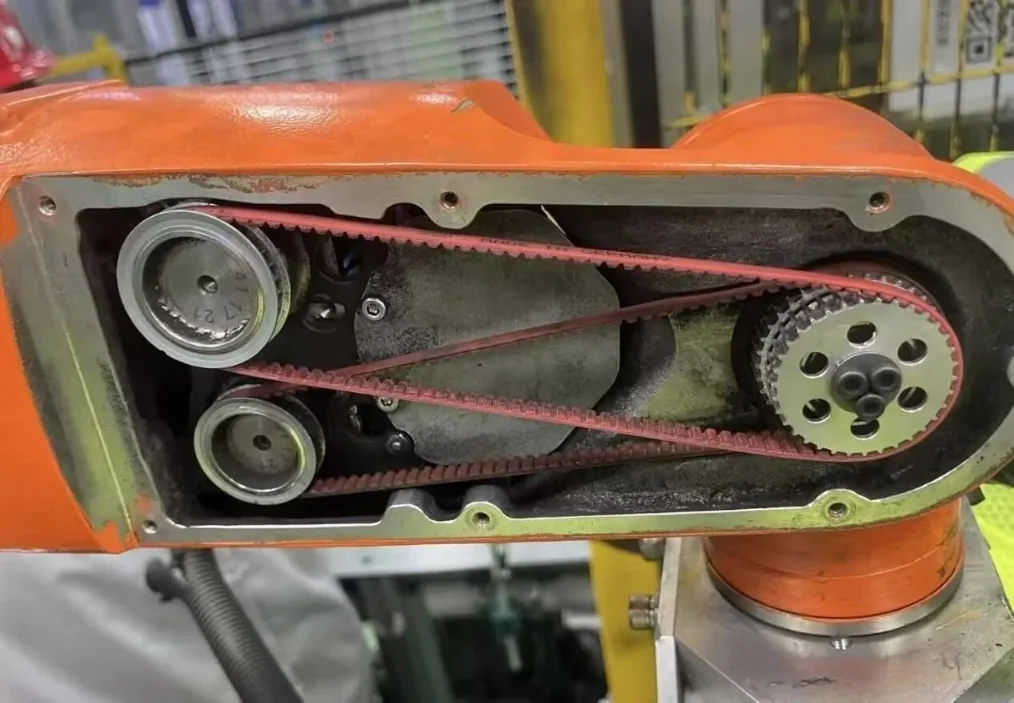
Repair Guide · 2026-09-12
When the KUKA KR10 R1420 Axis 4 reducer 00-200-827 exhibits abnormal noise, vibration, backlash, or positioning deviation, it is necessary to check lubrication, bearings, gears, and motor connections.
Read article →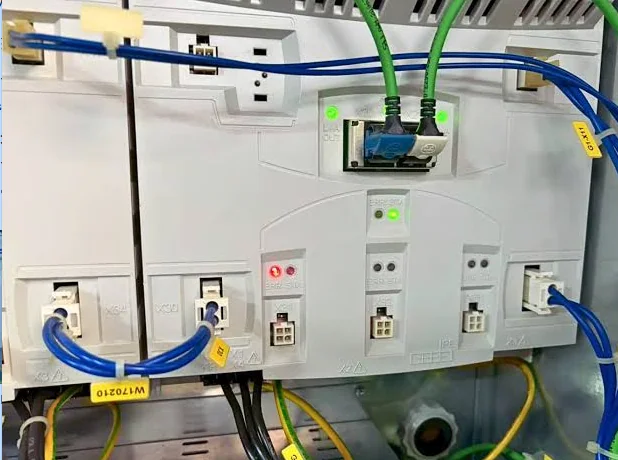
Maintenance Guide · 2026-09-12
When the KUKA 00-138-382 connection cable ages, experiences broken cores, or has damaged connectors, it may cause specific posture alarms, communication interruptions, and servo enable failures in the robot.
Read article →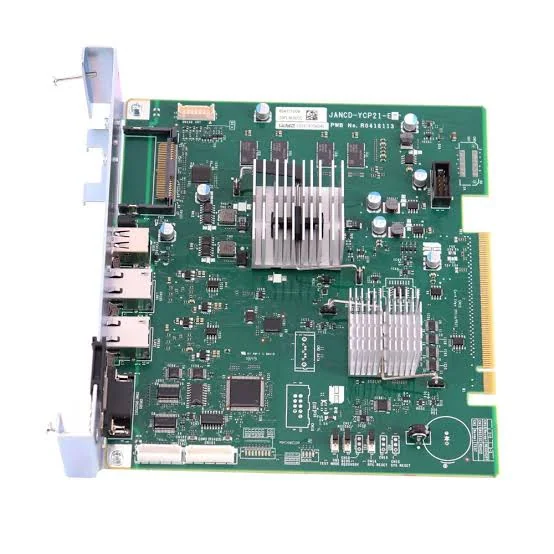
Repair Guide · 2026-09-12
When the Yaskawa JANCD-YCP21-E board experiences controller startup anomalies, communication interruptions, board offline status, or system errors, the power supply, backplane, connectors, and system configuration should be checked.
Read article →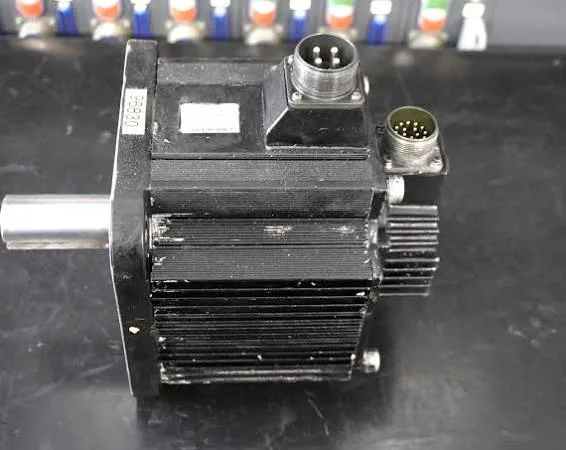
Maintenance Guide · 2026-09-12
When the Yaskawa SGMGH-20ACA61 servo motor experiences overheating, abnormal bearing noise, brake not releasing, or abnormal position feedback, both the drive parameters and mechanical load should be checked simultaneously.
Read article →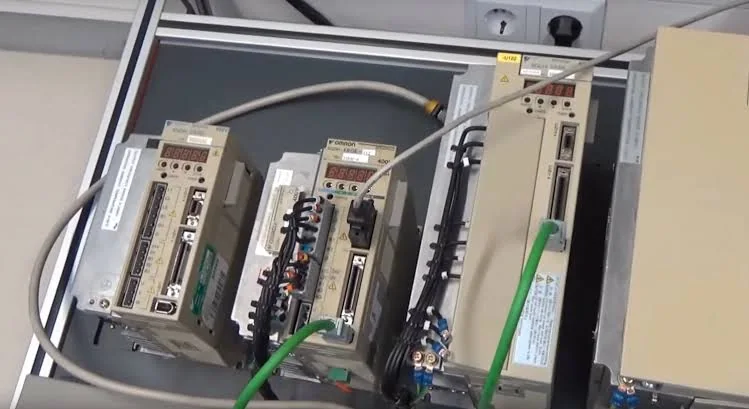
Repair Guide · 2026-09-12
When a Yaskawa SGDM-20ADA-V servo drive experiences overcurrent, overload, feedback abnormalities, or stops during operation, troubleshooting should follow the sequence of power supply, motor, encoder, and load.
Read article →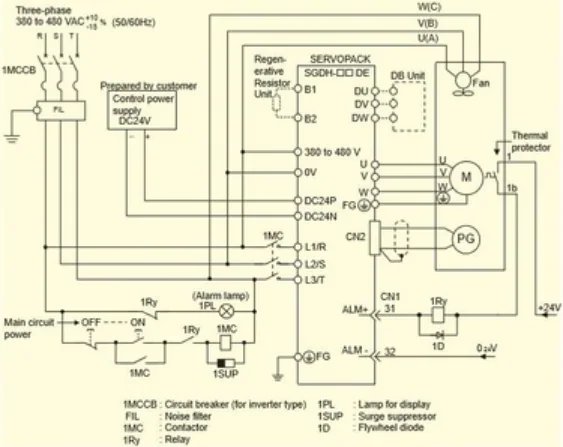
Maintenance Guide · 2026-09-12
When the Yaskawa SGDH-04AE-OY fails to power on, the servo fails to enable, the motor vibrates, or the drive alarms, the power supply, parameters, motor, encoder, and mechanical load should be checked in sequence.
Read article →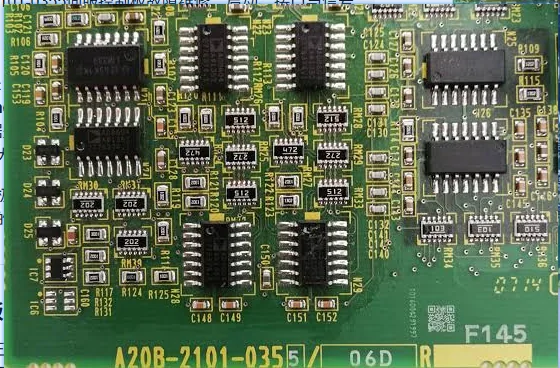
Repair Guide · 2026-09-12
When a FANUC A20B-2101-0355 servo control side board experiences issues such as the board not being recognized, no interface output, or abnormal drive control, the first step is to verify the power supply, connections, and the associated main unit.
Read article →