Robot Information · 2026-09-16
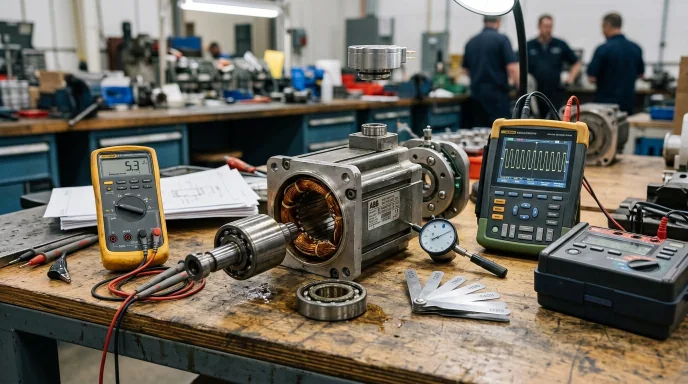
ABB servo motor faults should be diagnosed by combining encoder feedback, brake operation, bearing noise, winding insulation, and temperature rise tests to distinguish between motor, cable, and drive issues.
Read article →
Robot Information · 2026-09-16
ABB robot maintenance cycles should be established based on operating hours, load, speed, dust, temperature, and production cycle, covering the control cabinet, robot body, cables, and safety functions.
Read article →
Robot Information · 2026-09-16
ABB robot repair should first distinguish between controller, drive system, servo motor, teach pendant, body mechanical, and peripheral interlock faults, then formulate a detection and repair plan.
Read article →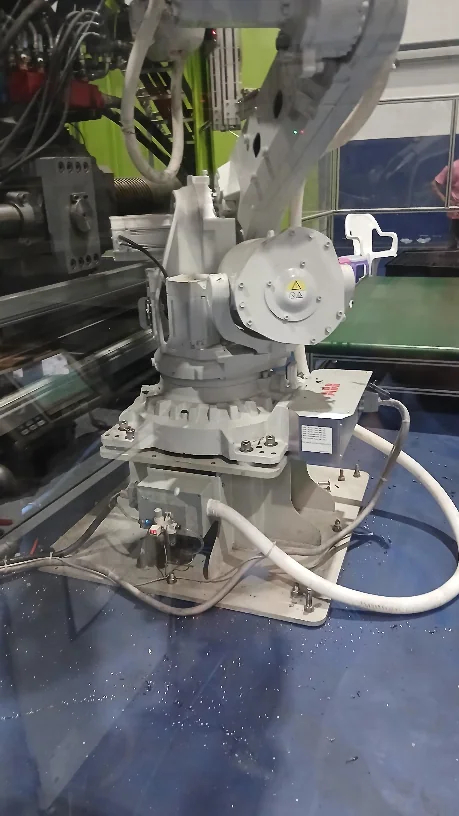
Robot Information · 2026-09-14
Looseness in the robot base or base foot connections can cause vibration, trajectory deviation, changes in repeat positioning, and mechanical shock. The foundation, bolt preload, and mounting surface should be inspected.
Read article →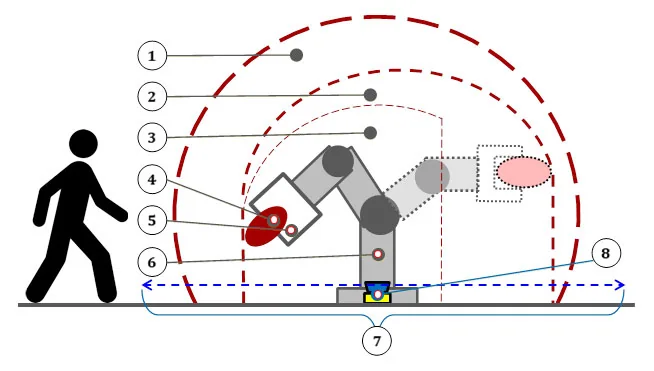
Robot Information · 2026-09-14
Robot safety zones and soft limits should be set by considering the mechanical range, fencing, personnel pathways, peripheral equipment, and stopping distance, and then verified through low-speed and automatic modes.
Read article →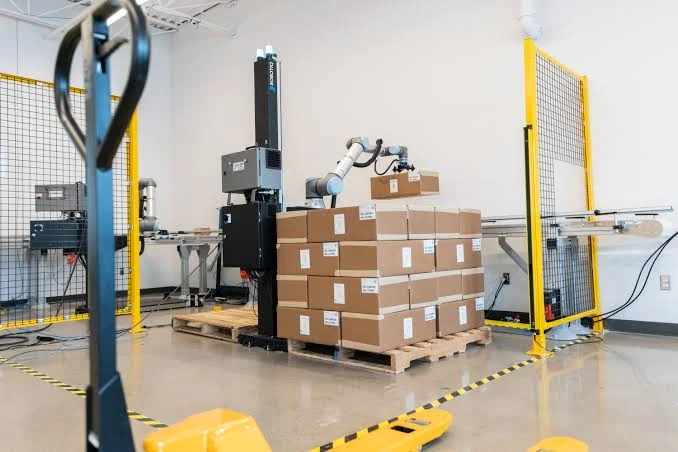
Robot Information · 2026-09-14
Progressive layer offset in palletizing positions may originate from workpiece coordinates, product dimensions, fixture center, gripping posture, conveyor positioning, and cumulative errors in the palletizing program.
Read article →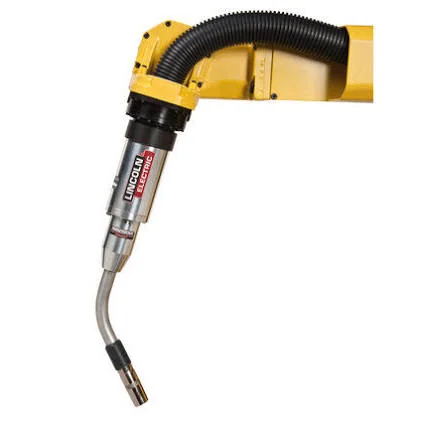
Robot Information · 2026-09-14
Unstable arc initiation in welding robots may originate from the welding power source, wire feeding, welding torch, grounding, process parameters, and robot interface signals, requiring troubleshooting along the process chain.
Read article →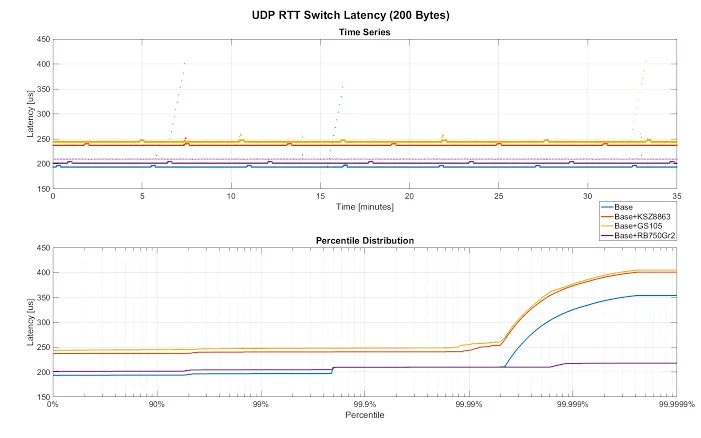
Robot Information · 2026-09-14
For intermittent robot network dropouts, check the physical link, switch ports, IP conflicts, communication cycles, network load, and electromagnetic interference, rather than just replacing the communication board.
Read article →
Robot Information · 2026-09-14
Before upgrading a robot system, confirm hardware compatibility, software version, license options, complete backup, communication equipment, and rollback media to avoid missing functions after the upgrade.
Read article →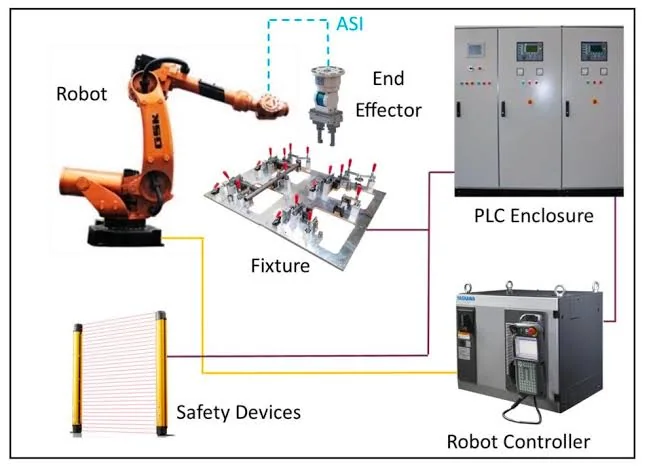
Robot Information · 2026-09-14
After an abnormal power outage in the control cabinet, inspect the power supply, fuses, power module, stored data, zero point status, and alarm log, then restore robot operation in stages.
Read article →
Robot Information · 2026-09-14
Robot brakes are responsible for holding position during shutdown and preventing falls during power loss. Checks should include release voltage, coil, mechanical clearance, holding capacity, and the condition of related cables.
Read article →
Robot Information · 2026-09-14
The robot maintenance cycle should consider calendar time, operating hours, motion cycles, load, environment, and historical failures simultaneously, and cannot rely solely on a fixed annual cycle.
Read article →